When is an RS485 robot battery integration actually working? Use three tests: the controller receives replies, the decoded values are correct, and the controller notices when the data stops updating. A voltage reading on the screen is still a long way from meeting all three.
If you already have a problem, first work out which kind it is: no reply at all, replies with the wrong data, or a link that drops only after the robot starts working. Each one points to a different place to look.
Get the protocol for the battery you are testing
RS485 only defines the electrical interface. It doesn’t define how the controller queries the battery or what each byte in a reply means. So even when both the battery and the controller have RS485 ports, the software may still need adapting. TI’s RS-485 basics document explains the difference between these two layers clearly.
Ask the battery supplier for two things: the interface pinout, and the communication protocol that matches the sample’s BMS (battery management system) and firmware version. First confirm whether it uses Modbus RTU or the supplier’s own protocol. Even with Modbus, you need this battery’s register map to know which addresses hold voltage, current and alarms.
It also helps to get a sample query and the expected reply. The controller engineer can then get the raw bytes working before building the display and return-to-charge logic. Also ask whether the controller polls the battery or the battery sends data on its own. If both sides wait for the other to start, the program shows no errors, but no data ever arrives.
No reply at all: check from the wiring to the message
Power down according to the equipment’s service procedure, then compare the actual harness with the interface drawings for both ends: pin numbers, signal definitions and any required reference (ground) connection. A plug that fits doesn’t mean the pins match. Check the signal polarity against the documents too, rather than wiring by the A and B labels alone.
Next, check the baud rate, data bits, parity and stop bits. For a query-and-reply protocol, also check the address, command, frame length and checksum being sent, how long the battery needs after power-up before it can reply, and how long the controller waits. If the command format is right but the address is wrong, sending it again and again won’t get a reply.
If communication works on the bench with a short cable but becomes unreliable once the battery is installed in the robot, compare what changed: cable routing, connectors, the reference connection and the termination resistor setup. Incorrect termination can cause signal reflections, but adding a resistor without understanding the existing circuit can create new problems. TI’s RS-485 design guide covers these electrical issues; the actual wiring should still follow the battery and controller interface drawings.
Plausible values can still be decoded wrong
During integration, look at the raw replies and the decoded values side by side. That’s where scaling and byte-order errors show up most easily. Suppose the protocol defines voltage in units of 0.1 V. A raw value of 256 then means 25.6 V. If it is mistakenly converted as millivolts, the screen will show 0.256 V.
Some errors are harder to spot. The current magnitude may be right while the sign for charge and discharge is reversed. A temperature value may look normal but come from the BMS board rather than the cells you meant to monitor. Before judging whether a value is right, find out exactly what the field represents.
| Data field | What to look up in the protocol | Why it matters |
|---|---|---|
| Voltage and current | Data type, byte or word order, scaling, units and sign | Beyond the value range, the current direction must also be read correctly. |
| State of charge (SOC) | Scale, invalid values and update method | A missing or outdated reading must not be treated as the current charge level. |
| Temperature | Sensor location, units and encoding | Temperatures from different locations describe different parts of the pack. |
| Alarms and status | Meaning of each status bit, and the conditions for setting and clearing it | Communication timeouts, battery alarms and protection events need to be handled separately. |
Besides normal values, check how the protocol marks invalid or unavailable data, so that “not supported” isn’t displayed as a real measurement. The table lists common items to check; not every BMS provides all of them.
After startup, charging or a dropout, can the data still be trusted?
Suppose the last valid reply showed 60% charge, and then communication dropped. The robot keeps using power, but the screen may stay at 60%. The controller needs to record when it received the last valid message so it can tell current data from an older stored reading.
Set the timeout based on the protocol’s update or reply interval and the robot’s operating requirements. What the equipment does after a timeout, and which conditions must be met before it resumes, should also be written into the program. Sending one more query doesn’t turn old battery data into valid new data.
Using the controller software you plan to ship, test communication during startup, normal operation and charging. If the battery design includes sleep and wake-up, test those transitions as well. Lost replies and recovery can be checked with controlled communication tests or simulation; there is no need to trigger an electrical protection event just to test a timeout. After the link comes back, confirm that new valid data has replaced the old readings and that the robot only resumes work once the agreed recovery conditions are met. Getting a reply again doesn’t mean the equipment can safely resume.
How alarms and shutdowns work together is best written into the protocol as well. For predictable situations such as low charge or high temperature, the BMS gives an early warning so the robot has time to slow down, return to charge or stop safely. For serious faults such as a short circuit, it disconnects immediately for safety. The controller needs to know what to do after each type of alarm.
When the robot stops, put controller events, battery messages and any available voltage and current measurements on one timeline. Did the supply drop first, did the BMS report protection first, or did the controller stop because it lost data? Communication logs can’t always explain a power problem, but the order of events tells you where to look next.
Check the interface details when you select a battery
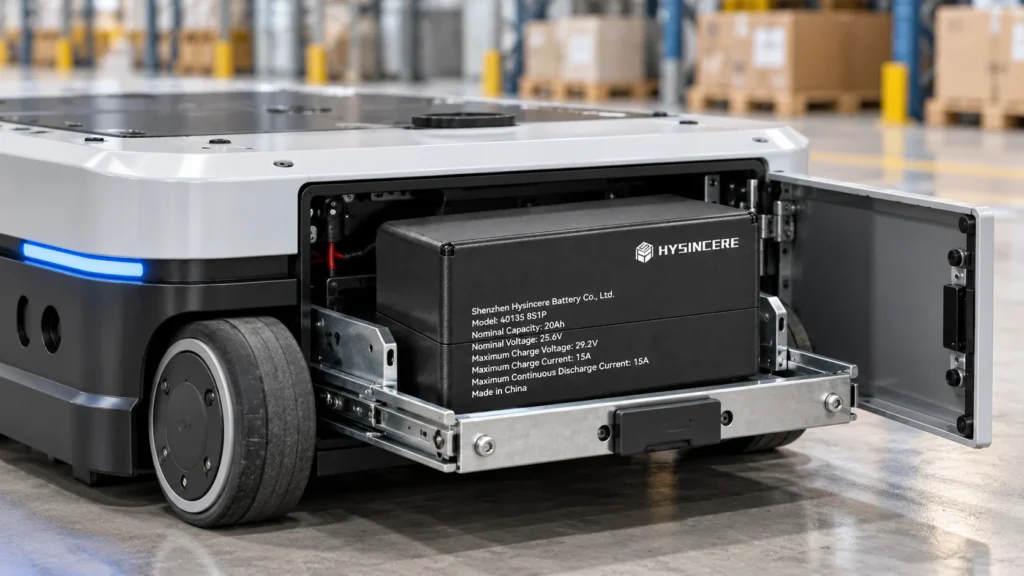
Take Hysincere’s 40135 8S1P 20Ah 25.6V Robot Lithium Battery Pack as an example. It is rated at 25.6 V, 20 Ah and 512 Wh, with a maximum continuous discharge current of 15 A, a 5-second peak discharge current of 20 A and an RS485 communication interface. These figures are enough for an initial selection; how the controller is adapted depends on the matching pinout and protocol. Load, capacity and charging requirements can be checked against our robot battery selection guide.
If the communication content needs to follow your controller’s protocol, prepare the protocol document, pin definitions, baud rate, message interval, data units and fault definitions, and ideally provide a controller for integration testing. We will map SOC, voltage, current, temperature, allowed current, alarms and charge/discharge permissions, then test together how the whole machine behaves under abnormal conditions.
Once integration works, keep a set of working queries and replies, along with the battery model, BMS firmware, controller software version and test results. If a field or update interval changes later, you can retest against that record instead of guessing what the configuration was. For the rest of the equipment checks, see our guide to custom battery pack sample approval.
Discuss Your Battery Interface
Tell us which controller you use and what happens when it communicates with the battery. You can send protocol documents or logs to the email address on our contact page.
Communication Integration FAQ
Which communication interfaces do Hysincere batteries support? Can they use CAN or CANopen?
UART, CAN, RS485 and SMBus can all be developed per project, and CANopen is adapted to the host's requirements. CANopen is a higher-layer protocol built on CAN, so a CAN port doesn't automatically mean CANopen support. We first confirm the messages, wiring and software versions, then decide whether an existing solution fits or custom development is needed.
How accurate is the state of charge (SOC) reading?
SOC is calculated by the BMS, not measured directly. Its accuracy depends on current sensing, capacity calibration, temperature, aging and calibration. At the start of a project, agree on how accuracy will be measured: under which operating conditions, temperatures and calibration state, against which reference, and what error counts as acceptable. Then test using that method. For an AGV, accuracy in the low-charge range matters most, because it decides when the vehicle goes back to charge.
Can the battery accept regenerative braking current from the robot?
Regenerative braking charges the battery, so it depends on whether the battery can accept charge at that moment. When it is full or cold, it can't. The controller then needs to limit regenerative braking or send the excess energy to a braking resistor, rather than relying on the BMS to disconnect suddenly. During sample testing, test downhill runs with a full battery and hard braking specifically.
The communication port is RJ45. Can I use a standard network cable?
Not necessarily. RJ45 ports look the same, but the pin assignments can differ. Use the communication cable that matches the battery and controller interface drawings rather than any network cable. If the battery has DIP switches, they usually set the address, master/slave role or protocol; set them according to the wiring diagram.
The featured image is a robot application illustration created from a Hysincere battery product photo. Specifications for the 40135 8S1P 20Ah are taken from Hysincere's product data as of October 2026; follow the latest datasheet, interface drawing and communication protocol for that model when wiring and integrating. Message values in this article are examples.